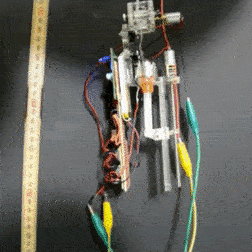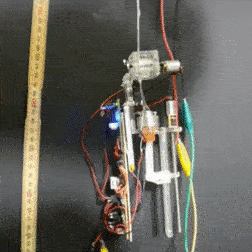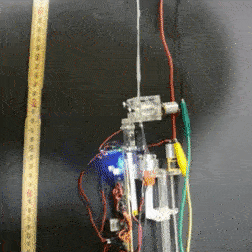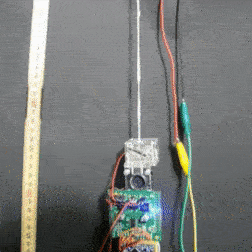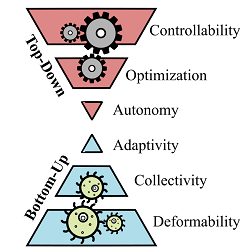
Adaptive Manipulation
Manipulation (not to be confused with the synonym term in psychology) is one of the fundamental functions for survival and adaptation in nature. From the most simple to the most complex, organisms have evolved certain body appendages to perform manipulation tasks that define their physical adaptation capabilities. It is no surprise that the understanding and analysis of this function has become one of the basic elements of robotics science, and my research. Taking the human hand as the template, I am specifically interested in the design and development of robotic manipulators that are both dexterous and physically compliant. I achieve this goal by combining rigid and soft materials, and applying machine learning methods to find optimum design and control parameters.
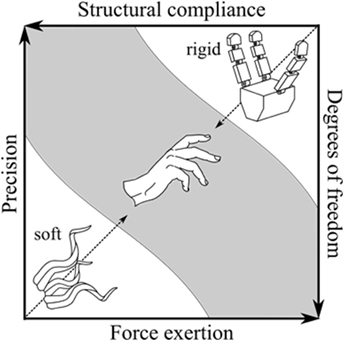
The common principles of physically adaptive manipulators establish a balance between damping, forces, precision, and compliance.
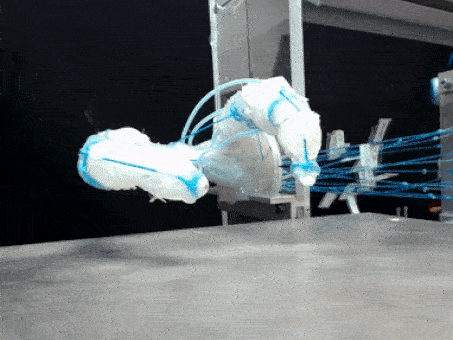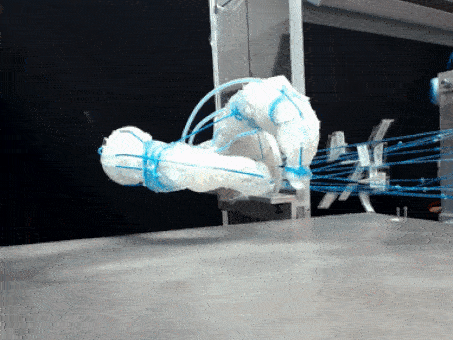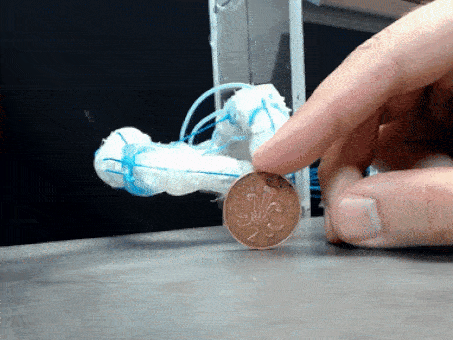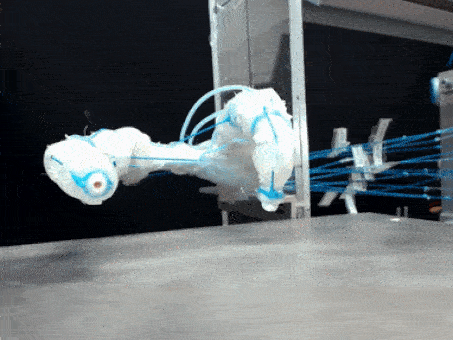
The hybrid use of hard and soft materials allows the robotic manipulators to perform anthropomorphic tasks.